
GAME DETAIL
SITL Forge – External FC: iNAV
種別:DLC
発売日:2026年6月15日
日本語対応未確認
1,592円
Steamレビュー
レビュー不足または未評価
100.0%
1件
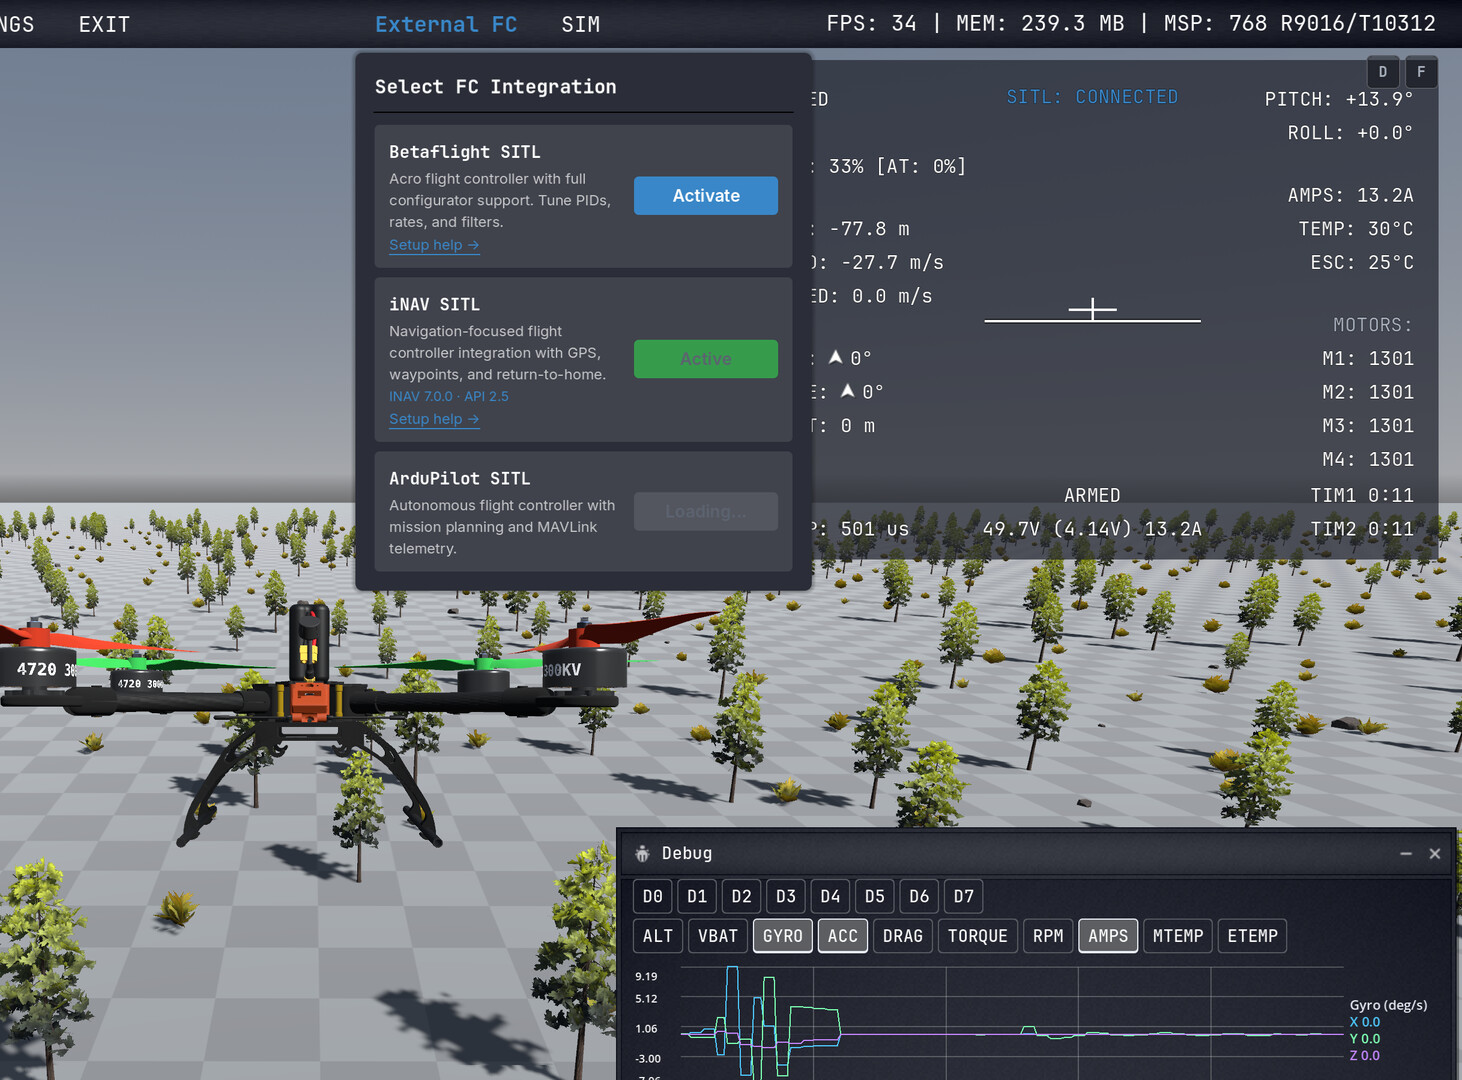
Adds a software-in-the-loop bridge to iNAV firmware. Replaces the built-in flight controller with the real firmware running on your PC, with simulated GPS and compass — so you can test navigation modes (position hold, return-to-home, waypoints) and tune PIDs and rates without risking real hardware.
このゲームについて
Steamの詳しい説明を読む
This DLC adds a software-in-the-loop bridge between SITL Forge - FPV Laboratory and iNAV firmware running on your PC. The built-in PID controller is replaced with the real firmware, so you fly, navigate, and tune against the same code that runs on real hardware — driven by the simulator's 1000Hz physics model, calibrated against real bench measurements.
Requires the base app: SITL Forge - FPV Laboratory.
---What This DLC Adds
MSP-based HITL bridge — the firmware drives the simulator through iNAV's standard MSP_SIMULATOR protocol
Per-motor outputs polled from the firmware, smoothed into the 1000Hz physics step
50Hz RC channel link — joystick or RC transmitter feeds the firmware's stick inputs
Simulated GPS and compass — unlocks iNAV's navigation modes: position hold, altitude hold, return-to-home, waypoint missions, and auto-launch
One-click mode switch — flip between built-in SIM and external firmware in-app
---A Controlled Environment for Navigation and Tuning
iNAV is built around navigation, and so is this integration. Test GPS-driven flight modes and tune the firmware in a simulator that aims to approximate real airframe behavior as closely as possible — without risking hardware on every change. The behavior you see is driven by the same firmware code you'll flash to your aircraft, running against a physics model fitted to real bench data.
Fly position hold, return-to-home, and waypoint missions against simulated GPS
Iterate on PID gains, rates, and filters without crashing real hardware
Probe failsafe behavior by simulating sensor and signal loss
Reproduce tricky navigation and tuning issues in a controlled environment
---Technical Details
MSP V2 link over TCP between simulator and firmware (port configurable in-app)
MSP_SIMULATOR HITL state exchange with the firmware's sensor and navigation stack
Simulated GNSS and magnetometer feed the firmware's estimator and navigation modes
Coordinate transform handled in-engine (Godot Y-up ↔ aviation NED)
Per-sensor failure simulation (gyro, accelerometer, barometer, compass, GPS) for failsafe testing
---Compatibility
You provide your own iNAV install. The iNAV SITL flight controller ships inside the free, open-source iNAV Configurator — there is nothing extra to build. Tested with iNAV 9.0. This DLC does not include or distribute iNAV binaries. Setup details are available in the iNAV project's SITL documentation , and in-app setup notes are included.
The iNAV Configurator can stay connected over TCP while you fly — for live PID tuning and telemetry — alongside the simulator link.
---
This DLC is an independent integration. It is not affiliated with, endorsed by, or sponsored by the iNAV project. "iNAV" is a trademark of its respective owners and is referenced here only to identify the firmware this integration connects to.
スクリーンショット
評価・レビュー
全体レビュー レビュー不足または未評価 好評率 100.00% / 1件 取得:2026年9月4日 14:47
ATTENTION
注目度メトリクス
プレイヤー推移
データ蓄積中 24時間平均選択した期間に観測データはありません。
Steamフォロワー推移
2件以上で集計 直近7日選択した期間に観測データはありません。
プレイヤー数とフォロワー数は意味と単位が異なるため、 別々の時系列として表示しています。補間した値は使用していません。
発売後注目度の基礎指標 発売済みタイトルのため、現在プレイヤー数・ピーク値・Steamフォロワー数を組み合わせて勢いを観測します。
| 指標 | 現在値 | 観測状況 |
|---|---|---|
| 現在プレイヤー数 | 未集計 | 最終観測:未集計 |
| 24時間ピーク | データ蓄積中 | 未集計・直近7日 0件 |
| Steamフォロワー数 | 未集計 | 最終観測:未集計 |
| 7日フォロワー増加 | 2件以上で集計 | 未集計・直近7日 0件 |
PlayMEXが保存した観測値です。取得時刻と観測数を あわせて確認できます。
ジャンル・機能
機能カテゴリ
#category_playable_at_your_own_paceいつでもセーブ可能カスタム音量調整カメラの快適性ダウンロードコンテンツテキストサイズの調整ファミリーシェアリングフルコントローラサポート時間制限付き入力なしでプレイ可能色のオプション難易度の調整
ゲームライフログ
所有ゲームとして同期されると、 このゲームの記録を残せます。